Product Details
Place of Origin: China
Brand Name: RION
Certification: CE, ISO,ROHS
Model Number: HDA446T
Payment & Shipping Terms
Minimum Order Quantity: 1
Price: $56.00/Pieces
Packaging Details: packing carton
Delivery Time: 5~8 work days
Payment Terms: T/T
Supply Ability: 1000 pcs/month
Measure Axis: |
X Axis / Y Axis / Z Axis |
Response Time: |
0.01S |
Waterproof Level: |
IP67 |
Weight: |
≤165g (Without Cable) |
Power-on Startup Time: |
≤3.5S |
Range: |
±4g / ±16g Optional |
Measure Axis: |
X Axis / Y Axis / Z Axis |
Response Time: |
0.01S |
Waterproof Level: |
IP67 |
Weight: |
≤165g (Without Cable) |
Power-on Startup Time: |
≤3.5S |
Range: |
±4g / ±16g Optional |
Built around an imported core control unit, the sensor operates on the capacitive miniature pendulum principle. When the unit is inclined, earth gravity produces a component on the corresponding pendulum, changing its capacitance. The capacitance is amplified, filtered and converted to obtain the tilt angle.
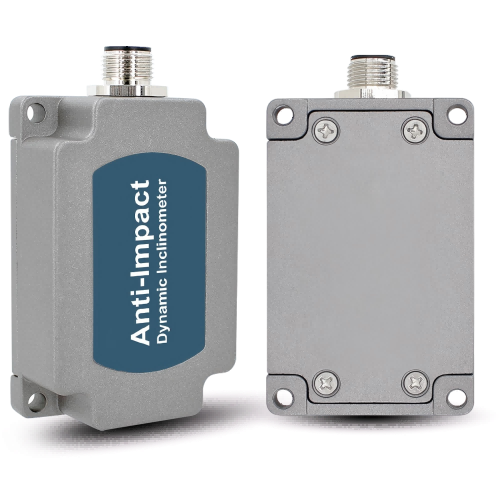
The HDA446T is a new-generation digital MEMS dynamic tilt sensor built to measure the attitude of a moving carrier — roll, pitch and azimuth — and equally suited to tilt measurement on machinery that is running or vibrating.
At its core are a high-precision accelerometer and gyroscope, paired with an integrated Kalman filter that reports the carrier's motion data in real time while it is moving or vibrating. RS485, RS232 and TTL signal outputs are available as options, so the sensor scales easily into different system architectures.
Measurement is non-contact. The sensor outputs the current attitude and tilt angle in real time, with no need to locate a reference surface or track the relative movement between two planes. Onboard high-precision AD conversion and gyro units compensate in real time for non-linearity, orthogonal (cross-axis) coupling, temperature drift and centrifugal acceleration. This largely removes the centrifugal error caused by motion-induced acceleration, lifting dynamic measurement accuracy and keeping the sensor stable through long-term, complex motion and in harsh environments.
A dual-mode dynamic/static sensor with strong immunity to external electromagnetic interference, the HDA446T takes on large-scale, high-shock and high-vibration industrial conditions — a dependable choice for industrial automation control and attitude measurement.
| HDA446T | Condition | Parameter | |
| Measure range | - | Roll±180°, pitch±90°, azimuth±180° (initial value at power-down is 0°) | |
| Measure axis | - | X axis / Y axis / Z axis | |
| Roll&Pitch Static accuracy1) | @25℃ | ± 0.05° | |
| Roll&Pitch Dynamic accuracy(rms) | @25℃ | ± 0.1° | |
| Gyro | range | - | ±300°/s |
| Zero bias stability (10s Smooth) | - | 8.5°/h | |
| Angle random walk coefficient(Allan) | - | 0.25°/sqrt(h) | |
| Acceleration | range | - | ±4g / ±16g optional |
| Bias stability(10s mean) | - | 0.02mg | |
| Bias instability(Allan) | - | 0.005mg | |
| Speed random walk coefficient(Allan) | - | 0.005m/s/sqrt(h) | |
| Zero point temp. Coefficient2) | -40~85℃ | ±0.01°/℃ | |
| Sensitivity temp. Coefficient3) | -40~85℃ | ≤100ppm/℃ | |
| Power-on startup time | ≤3.5S | ||
| Response time | 0.01S | ||
| Output signal | RS485/RS232/TTL | ||
| Electromagnetic compatibility | According to EN61000 and GBT17626 | ||
| MTBF | ≥ 98000 hours / time | ||
| Insulation resistance | ≥100 Megohm | ||
| Impact resistance | 100g @ 11ms,3 axial direction (half sinusoid) | ||
| Anti-vibration | 10grms / 10~1000Hz | ||
| Waterproof level | Standard IP67, optional IP68 and corrosion-resistant IP68 protection level | ||
| Weight | ≤165g (Without cable) | ||
1)Accuracy: refers to the root mean square difference between the measured and actual angle value by multiple measurements (>16 times) under normal temperature. | |||
Q1: What is the HDA446T dynamic tilt sensor used for?
The HDA446T is designed to measure the real-time attitude of moving or vibrating carriers. It provides roll, pitch, and azimuth measurements for engineering machinery, railway locomotives, drilling equipment, ships, and other industrial applications.
Q2: Can the HDA446T measure tilt angles while equipment is moving or vibrating?
Yes. The HDA446T integrates high-precision accelerometer and gyroscope units with a Kalman filter algorithm to measure carrier attitude under dynamic and static conditions.
Q3: What attitude parameters can the HDA446T measure?
The sensor measures three attitude parameters:
These measurements help monitor the orientation and attitude changes of moving equipment.
Q4: What is the dynamic measurement accuracy of the HDA446T?
The dynamic accuracy for roll and pitch is ±0.1°, while the static accuracy is ±0.05°. Actual measurement performance may depend on operating conditions and installation.
Q5: What output interfaces are available?
The HDA446T supports optional RS485, RS232, and TTL output interfaces. Customers can select the appropriate communication interface according to their control system requirements.